Differentiable Kinematics for Analysis and Gradient-Based Design of Generalized Parallel Mechanisms Z. Xia, J. W. Zhang, Y. Xing, Chunxu Tian, D. Zhang Mechanism and Machine Theory Accepted 2026 Link ↗
Kinematic Neural Networks: A New Paradigm for Embodied Mechanical Intelligence IEEE Robotics and Automation Letters Accepted 2026 Link ↗
Object-Centric Alignment and Deformable Fusion for Unaligned RGBT Anti-UAV Tracking Q. Ren, D. Zhang, Chunxu Tian, D. Zhang ACM Multimedia 2026 (ACM MM) Accepted 2026 Link ↗
Physically Aware Generative Design for Spatial Mechanism Synthesis: A Differentiable Diffusion-Refinement Framework IEEE Robotics and Automation Letters Accepted 2026 Link ↗
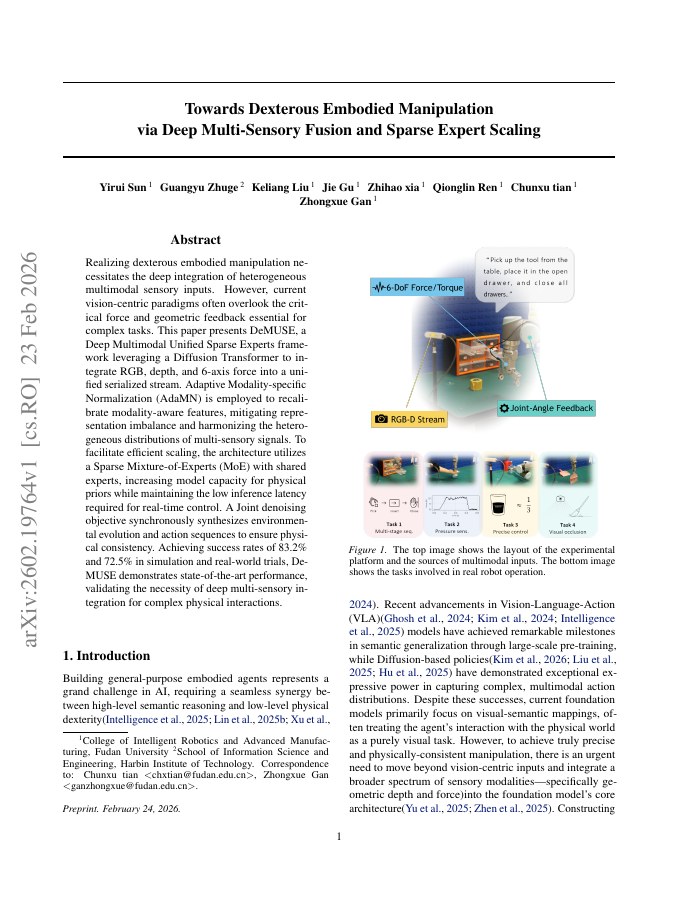
Towards Dexterous Embodied Manipulation via Deep Multi-Sensory Fusion and Sparse Expert Scaling K. Liu, J. Gu, Z. Xia, Q. Ren, Chunxu Tian, Z. Gan arXiv preprint arXiv:2602.19764 2026 Link ↗
Design and Analysis of a Quadruped Wheel-Legged Robot Based on Virtual Equivalent Parallel Mechanism Theory B. Wang, S. Liu, D. Zhang, Chunxu Tian Mechanism and Machine Theory Accepted; preprint: SSRN 6960319 2026 Link ↗
Reconfiguration-Complete Motion Primitives with Constructive Planning for Deformable Planar Modular Robots J. Gu, T. Wang, H. Gao, Y. Sun, Z. Xia, Chunxu Tian, D. Zhang arXiv preprint arXiv:2608.17324 2026 Link ↗
SANTS: A State-Adaptive Scheduler for World Action Models Y. Sun, G. Zhuge, K. Liu, J. Gu, X. Bing, Z. Gan, Chunxu Tian arXiv preprint arXiv:2605.27947 2026 Link ↗
Design and Kinematic Performance Analysis of a Novel Asymmetric 1T1R Parallel Robot Q. Zou, S. Zhang, Y. Shi, Y. Zhang, M. Jafari, G. Huang, Chunxu Tian 2026 7th International Conference on Artificial Intelligence, Robotics, and Control (AIRC) Pages 177-182 2026 Link ↗
Self-Reconfiguration Planning for Deformable Quadrilateral Modular Robots J. Gu, H. Gao, Z. Xia, Y. Sun, Chunxu Tian, D. Zhang IEEE Robotics and Automation Letters Vol. 11, No. 6, Pages 7300-7307 2026 Link ↗
Rhombot: Rhombus-shaped Modular Robots for Stable, Medium-Independent Reconfiguration Motion J. Gu, Y. Sun, Z. Xia, T. L. Lam, Chunxu Tian, D. Zhang arXiv preprint arXiv:2601.19529 2026 Link ↗
Mapping mechanical synthesis to a trainable task: A neural network approach for generalized parallel mechanisms Z. Xia, X. Lao, Chunxu Tian, D. Zhang Mechanism and Machine Theory Vol. 219, Article 106337 2026 Link ↗
Design and analysis of a Bricard-inspired dexterous hand based on generalized parallel mechanisms H. Li, B. Wang, Chunxu Tian, D. Zhang Mechanism and Machine Theory Vol. 219, Article 106340 2026 Link ↗
A Novel Reconfigurable Dexterous Hand Based on Triple-Symmetric Bricard Parallel Mechanism Chunxu Tian, Z. Huang, H. Li, B. Wang, J. Jia, Y. Sun, D. Zhang arXiv preprint arXiv:2603.00892 2026 Link ↗
基于深度信息的视频对象分割方法研究 D. Zhang, W. Zhong, Chunxu Tian Journal of Fudan University (Natural Science) DOI: 10.15943/j.cnki.fdxb-jns.20251121.001 2025 Link ↗
一种多模态可重构广义并联灵巧手的设计与分析 H. Li, Chunxu Tian, D. Zhang Journal of Fudan University (Natural Science) Vol. 64, No. 4, Pages 456-466 2025 Link ↗
Type synthesis of a class of parallel RCM manipulators based on concentric spherical surfaces geometric model L. Li, Chunxu Tian, Z. Xia, D. Zhang Mechanism and Machine Theory Vol. 209, Article 106011 2025 Link ↗
Design and analysis of pipeline inspection robot based on generalized parallel mechanisms Y. Xing, W. Ma, Chunxu Tian, D. Zhang Robotica Vol. 43, No. 10, Pages 3682-3700 2025 Link ↗
MODUR: A Modular Dual-reconfigurable Robot J. Gu, T. L. Lam, Chunxu Tian, Z. Xia, Y. Xing, D. Zhang 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Conference paper 2025 Link ↗
A Review on Kinematically Redundant Parallel Mechanisms With Configurable Platforms Chunxu Tian, D. Zhang SmartBot Vol. 1, No. 4, e70014 2025 Link ↗
UAUTrack: Towards Unified Multimodal Anti-UAV Visual Tracking Q. Ren, D. Zhang, Chunxu Tian, D. Zhang arXiv preprint arXiv:2512.02668 2025 Link ↗
A Novel Synthesis Method for the Design of Origami-Based Parallel Mechanisms Y. Xing, Chunxu Tian, B. Wang, D. Zhang 2025 IEEE International Conference on Robotics and Biomimetics (ROBIO) Pages 167-172 2025 Link ↗
Advances in generalized parallel mechanisms: Coupling, configurable, and articulated designs Z. Xia, Y. Xing, Chunxu Tian, D. Zhang Mechanism and Machine Theory Vol. 218, Article 106287 2025 Link ↗
A Reconfigurable Parallel Dexterous Hand Robot H. Li, Chunxu Tian, B. Wang and D. Zhang Invention Patent 2025103775113 2025 Link ↗
Optimal design of a generalized single-loop parallel manipulator with RCM characteristic considering motion/force transmissibility L. Li, Chunxu Tian, Z. Xia and D. Zhang Robotica Pages 1-17 2025 Link ↗
The novel synthesis of generalized parallel manipulators with 8R Kirigami-inspired configurable platform Y. Xing, Chunxu Tian, Z. Xia, J. Gu and D. Zhang Mechanism and Machine Theory Vol. 209 Pages 106003 2025 Link ↗
The novel synthesis method of decoupled generalized parallel mechanisms based on motion transmission Z. Xia, Chunxu Tian, Y. Xing, J. Gu, L. Li and D. Zhang Mechanism and Machine Theory Vol. 210 Pages 106019 2025 Link ↗
A Low-Inertia Bionic Robot Walking Parallel Mechanism and Walking Method Chunxu Tian, F. Gan, G. Yuan, C. Wang, C. Yuan and S. Jiang Invention Patent CN202410251126.X 2024 Link ↗
An Integrated Bionic Robotic Ankle Transmission Device G. Yuan, Chunxu Tian, J. Li and Y. Liu Invention Patent 202420743833.6 2024 Link ↗
Grinding Visualization Rendering Method, System, Device, and Storage Medium for Surgical Navigation D. Zhang, J. Liu, Z. Huang and Chunxu Tian Invention Patent 202411037487.0 2024 Link ↗
Femur Prosthesis Model Pose Initialization Method, System, Equipment and Storage Medium D. Zhang, J. Liu, Z. Huang and Chunxu Tian Invention Patent CN118924498A 2024 Link ↗
Research on the Structure Design Based on Cable Driven and Bounding Control Method of a Quadruped Robot with Double-Joint Spine J. Ma, Chunxu Tian, L. Li, D. Zhang Journal of Fudan University (Natural Sciences) Vol. 63, No. 6, Pages 711-723 2024 Link ↗
MOPARAS: A Modular Parallel Spherical Robot with Position-Adjustable Connectors J. Gu, T. Lam, Chunxu Tian, L. Li, Z. Xia, D. Zhang International Conference on Intelligent Robotics and Applications Pages 363-376 2024 Link ↗
The novel synthesis of mechanisms for continuous origami based on the topological graph theory Z. Xia, Chunxu Tian, L. Li and D. Zhang Mechanism and Machine Theory Vol. 204 Pages 105857 2024 Link ↗
The novel synthesis of origami-inspired mechanisms based on graph theory Z. Xia, Chunxu Tian, L. Li and D. Zhang Mechanism and Machine Theory Vol. 192 Pages 105547 2024 Link ↗
The novel synthesis of reconfigurable generalized parallel manipulators with kinematic redundancy Chunxu Tian, Z. Xia, L. Li, D. Zhang Mechanism and Machine Theory Vol. 201, Article 105748 2024 Link ↗
Analysis of the Velocity of Two-Layer Generalized Parallel Manipulators Chunxu Tian, Z. Huang, H. Li, F. Chen 2024 IEEE International Conference on Mechatronics and Automation (ICMA) Pages 1694-1699 2024 Link ↗
A virtual parallel model for the buffer landing of multi-legged landing gear J. Liu, D. Zhang, Chunxu Tian, W. Ma, Z. Xia Mechanism and Machine Theory Vol. 200, Article 105724 2024 Link ↗
A family of generalized single-loop RCM parallel mechanisms: structure synthesis, kinematic model, and case study L. Li, D. Zhang, Chunxu Tian Mechanism and Machine Theory Vol. 195, Article 105606 2024 Link ↗
A Design and Prototype Verification of an Active Diameter-Varying Pipeline Inspection Robot W. Ma, D. Zhang, J. Liu, Chunxu Tian and Z. Xia Journal of Fudan University (Natural Sciences) Vol. 62, No. 5, Pages 627-636 2023 Link ↗
Graph Synthesis of Generalized Parallel Mechanisms with Coupling Sub-chains Chunxu Tian, L. Li, Z. Xia, D. Zhang Intelligent Robotics and Applications. ICIRA 2023 Pages 76-87 2023 Link ↗
A Novel Class of (3+2)-DOF Reconfigurable Generalized Parallel Mechanisms with Kinematic Redundancy Chunxu Tian, L. Li, Z. Xia, D. Zhang Mechanism and Machine Science. IFToMM WC 2023 Vol. 130, Pages 386-395 2023 Link ↗
A Four-Degree-of-Freedom Parallel Robot Chunxu Tian and D. Zhang Invention Patent CN202110517068.7 2022 Link ↗
A Parallel Robot Chunxu Tian, J. Ma, W. Ma, J. Gu and D. Zhang Invention Patent CN202210112092.7 2022 Link ↗
A Five-degree-of-freedom Parallel Mechanism with Large Rotation Angle Chunxu Tian, W. Ma, J. Ma and D. Zhang Invention Patent CN114406729B 2022 Link ↗
Multi-Functional UAV undercarriage and UAV Chunxu Tian, D. Zhang and W. Ma Invention Patent CN113086173B 2022 Link ↗
End-to-end SAR Ship Detection Method and System Y. Chen, Z. Xia Zhihao, Chunxu Tian, J. Liu, C. Wu Chenwei and D. Zhang Invention Patent CN114581755B 2022 Link ↗
A novel 6 DOFs generalized parallel manipulator design and analysis based on humanoid leg Z. Xia, D. Zhang, Y. Chen, Chunxu Tian, J. Liu, C. Wu Mechanism and Machine Theory Vol. 176, Article 105029 2022 Link ↗
A method for comprehensive performance optimization of four-leg landing gear based on the virtual equivalent parallel mechanism H. Tang, D. Zhang, Chunxu Tian Mechanism and Machine Theory Vol. 174, Article 104924 2022 Link ↗
An Approach for Modeling and Performance Analysis of Three-Leg Landing Gear Mechanisms Based on the Virtual Equivalent Parallel Mechanism H. Tang, D. Zhang, Chunxu Tian Mechanism and Machine Theory Vol. 169, Article 104617 2022 Link ↗
Structure synthesis of reconfigurable generalized parallel mechanisms with configurable platforms Chunxu Tian, D. Zhang, H. Tang, C. Wu Mechanism and Machine Theory Vol. 160, Article 104281 2021 Link ↗
Reconfigurable Generalized Parallel Mechanisms with Kinematotropic Linkages Chunxu Tian, D. Zhang, H. Tang, J. Liu 2021 7th International Conference on Mechatronics and Robotics Engineering (ICMRE) Pages 185-189 2021 Link ↗
Design and analysis of novel kinematically redundant reconfigurable generalized parallel manipulators Chunxu Tian, D. Zhang Mechanism and Machine Theory Vol. 166, Article 104481 2021 Link ↗
A Novel Terrain Adaptive Landing Gear Robot H. Tang, Chunxu Tian, D. Zhang Journal of Physics Conference Series Vol. 1924, Article 012021 2021 Link ↗
A multi-finger robot system for adaptive landing gear and aerial manipulation J. Liu, D. Zhang, C. Wu, H. Tang, Chunxu Tian Robotics and Autonomous Systems Vol. 146, Article 103878 2021 Link ↗
A Reconfigurable Parallel Robot Mechanism with Three Relative Degrees of Freedom Chunxu Tian, Y. Fang, H. Lin and S. Guo Invention Patent CN107498540B 2020 Link ↗
A novel class of generalized parallel manipulators with high rotational capability Chunxu Tian, D. Zhang, J. Liu Proceedings of the Institution of Mechanical Engineers, Part C Journal of Mechanical Engineering Science Vol. 234, No. 23, Pages 4599-4619 2020 Link ↗
A new family of generalized parallel manipulators with configurable moving platforms Chunxu Tian, D. Zhang Mechanism and Machine Theory Vol. 153, Article 103997 2020 Link ↗
Structural Synthesis and Performance Study of Generalized Parallel Mechanisms Chunxu Tian Thesis of Doctoral Degree Pages 1-145 2019 Link ↗
Design and analysis of a partially decoupled generalized parallel mechanism for 3T1R motion Chunxu Tian, Y. Fang, Q. J. Ge Mechanism and Machine Theory Vol. 140, Pages 211-232 2019 Link ↗
A Reconfigurable Parallel Mechanism with Five-Bar Kinematic Chains Chunxu Tian, Y. Fang, S. Guo and H. Qu Invention Patent CN105751202B 2018 Link ↗
Structure synthesis of reconfigurable parallel mechanisms with closed-loop metamorphic linkages Chunxu Tian, Y. Fang, S. Guo, H. Qu Proceedings of the Institution of Mechanical Engineers, Part C Journal of Mechanical Engineering Science Vol. 232, No. 7, Pages 1303-1316 2018 Link ↗
Structural synthesis of a class of two-loop generalized parallel mechanisms Chunxu Tian, Y. Fang, Q. J. Ge Mechanism and Machine Theory Vol. 128, Pages 429-443 2018 Link ↗
New Kinematic Structures for Two-Loop Generalized Parallel Mechanism Designs Chunxu Tian, Y. Fang, Q. J. Ge 2018 IEEE International Conference on Robotics and Automation (ICRA) Pages 956-961 2018 Link ↗
A class of reconfigurable parallel mechanisms with five-bar metamorphic linkage Chunxu Tian, Y. Fang, S. Guo, H. Qu Proceedings of the Institution of Mechanical Engineers, Part C Journal of Mechanical Engineering Science Vol. 231, No. 11, Pages 2089-2099 2017 Link ↗
Structural synthesis of parallel manipulators with coupling sub-chains Chunxu Tian, Y. Fang, Q. J. Ge Mechanism and Machine Theory Vol. 118, Pages 84-99 2017 Link ↗
Structural synthesis of a class of 2R2T hybrid mechanisms Chunxu Tian, Y. Fang, S. Guo Chinese Journal of Mechanical Engineering Vol. 29, No. 4, Pages 703-709 2016 Link ↗
Optimization of the motion performanceof planar five-bar linkage using a genetic algorithm G. Huang, Y. Fang, H. Qu, Chunxu Tian Journal of Beijing Jiaotong University Vol. 39, No. 4, Pages 44-49 2015 Link ↗